Robotics & Autonomy Engineer

Aerial Robotics, PX4/ROS 2 & Wildfire Science

Originally from Colombia, I am a PhD student in Aerospace Engineering at the University of Maryland, College Park, working as a Graduate Research Assistant with the Department of Fire Protection Engineering (advised by Dr. Fernando Raffan-Montoya and co-advised by Dr. Lina Maria Castano). I engineer full-stack UAV autonomy, multi-modal aerial sensing (radiometric thermal + EO), high-fidelity physics simulations (Isaac Sim & Gazebo), and rapid emergency response systems.

Graduate Research Assistant — UMD Department of Fire Protection Engineering & Department of Aerospace Engineering (Advisors: Dr. Fernando Raffan-Montoya & Dr. Lina Maria Castano)
Technical Lead (Autonomy) — Team Crossfire, $11M XPRIZE Wildfire Competition
Origin & Location: Bogotá, Colombia 🇨🇴 • Based in College Park, MD, USA
Work Authorization: F-1 Visa (CPT & STEM-OPT Eligible)
Andrés Felipe Rivas Bolívar

Andrés Felipe Rivas Bolívar

Aerospace Engineering PhD • UMD College Park
UAV Autonomy PX4 / ROS 2 NVIDIA Isaac Sim Thermal Sensing Wildfire Autonomy
Finalist Winner — $5,000 USD Grant | 2026 WUI Fire Engineering Summit
Awarded in the Student Pitch Competition hosted by the SFPE Foundation & United Engineering Foundation for wildfire mitigation research. Co-developed with Adetola Ololade Nicole Koiki, supervised by Dr. Fernando Raffan-Montoya (FireTEC, UMD).
SFPE Announcement

Autonomous Aerial Systems for Extreme Environments

Uniting robotic flight dynamics, multi-spectral perception, and wildfire science to engineer robust, field-deployable aerial autonomy.

I am a PhD student in Aerospace Engineering at the University of Maryland, College Park, working as a Graduate Research Assistant with the Department of Fire Protection Engineering (advised by Dr. Fernando Raffan-Montoya in the FireTEC laboratory and co-advised by Dr. Lina Maria Castano in Aerospace Engineering).

My work closes the loop between first-principles multirotor flight dynamics, physics-based combustion modeling, and real-time aerial autonomy stacks. I design, build, and deploy complete autonomy pipelines capable of real-time fire detection, thermal georeferencing, optimized emergency evacuation alerts, and precision aerial suppression.

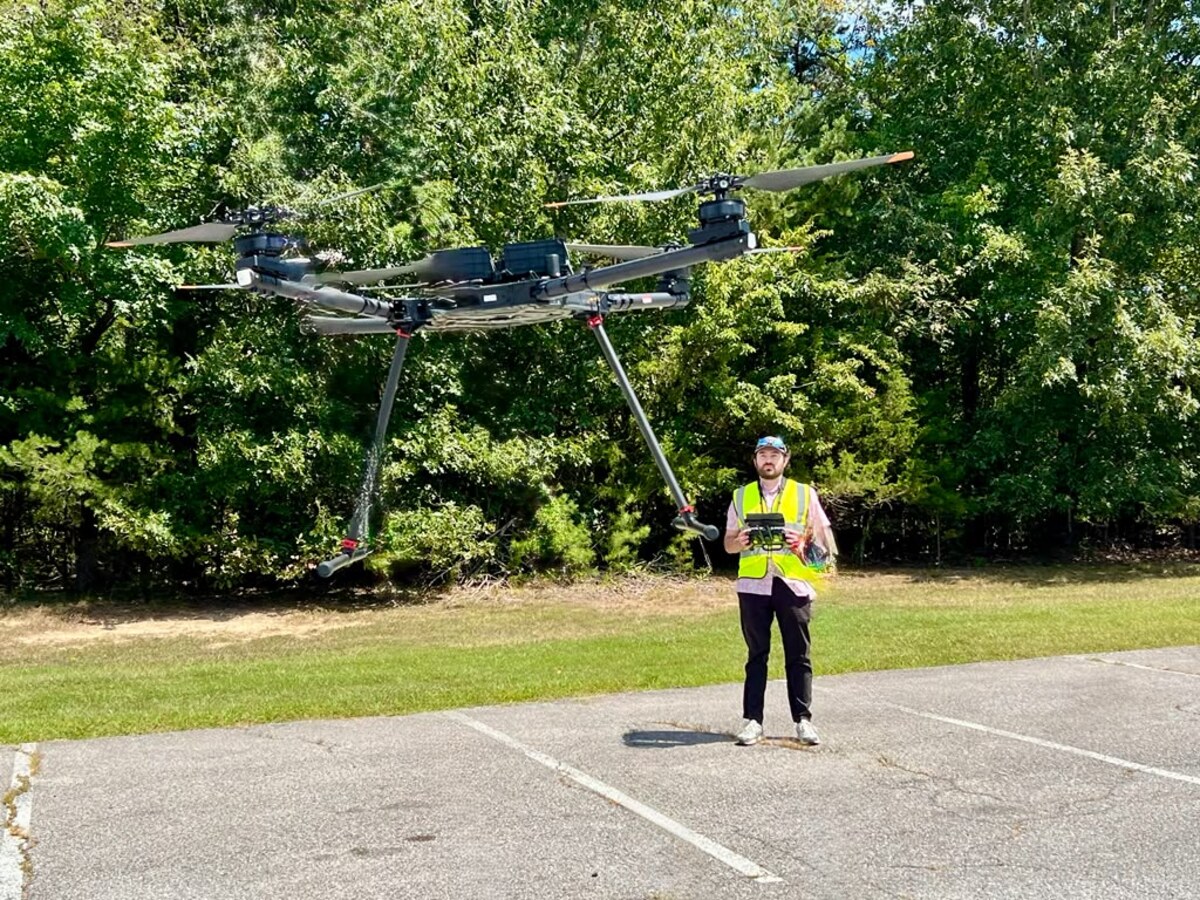
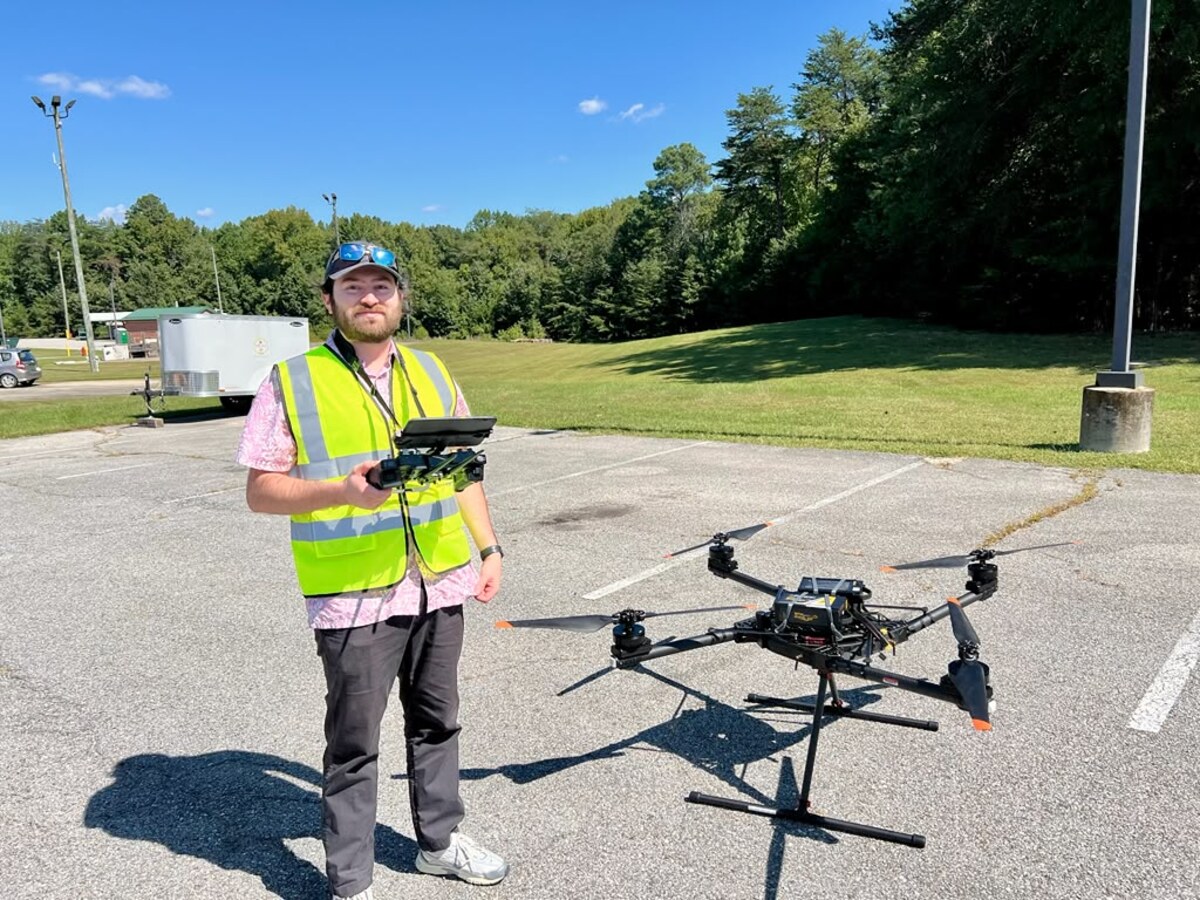
Beyond algorithms and digital twins, I conduct hands-on field robotics: tuning PX4 rate and PID controllers, integrating multi-spectral payloads (thermal IR + RGB), and operating research platforms like the Freefly Alta X in real-world wildfire suppression trials.

Fire Protection Eng. Aerospace Flight Dynamics Multi-Spectral Perception XPRIZE Wildfire

Flight Readiness & Field Trials

Andrés conducting field operations: pre-flight payload checks (left) and Freefly Alta X active hover flight trials (right).

Field-to-Simulation Autonomy Pipeline

A unified engineering framework bridging first-principles 6-DOF multirotor dynamics, combustion physics, digital twin simulations, telemetry networking, and multi-modal perception.

1. Python-Based 6-DOF Simulation
Rigid-Body Flight Dynamics
First-principles 6-DOF multirotor equations of motion, quaternion kinematics, rotor momentum theory, motor time-constant lag, and ground-effect modeling in Python and C++ for control verification.
Python 6-DOF Flight Dynamics
2. Wildfire Modeling & Propagation
ELMFIRE Fire Science Engine
Coupled ELMFIRE raster models simulate dynamic 1m surface and crown fire spread, flame temperature inversions, wind-shear gusts, and fuel moisture over realistic terrain footprints (e.g., Concow, CA).
ELMFIRE Combustion Physics
3. High-Fidelity Physics Simulation
NVIDIA Isaac Sim 6 & Gazebo Harmonic
Renders layered Briggs smoke plumes with NVIDIA Flow, canopy-aware thermal radiance, and dynamic structure combustion at 250 Hz physics lockstep with zero-jitter gimbal stabilization.
Isaac Sim 6.0 Pegasus / PhysX
4. Autopilot & State Estimation
PX4 Autopilot SITL/HITL & EKF2
PX4 executes lockstep flight control. EKF2 fuses VIO, GPS, barometric altitude, and IMU data with retuned motor time constants and exponential stick smoothing.
PX4 Autopilot MAVLink / EKF2
5. Robotics Telemetry & Networking
ROS 2, Micro-XRCE-DDS & RTSP
Multi-protocol airborne telemetry network: bridges PX4 uORB messaging into ROS 2 Humble via Micro-XRCE-DDS, with low-latency RTSP video streaming and UDP/TCP telemetry to Ground Control Stations.
Telemetry Network ROS 2 / MAVLink
6. Multi-Modal Perception & Local VLMs
Thermal IR, YOLO11 & 35B VLM Reasoning
Radiometric thermal IR (mono16) and 4K EO cameras feed real-time fire detection models (YOLO11), paired with local Vision-Language Models (VLMs) and multi-spectral perception for edge scene reasoning under degraded visual environments.
Thermal IR Local VLMs (35B)

Research & Engineering Projects

Key technical systems across autonomous evacuation routing, wildfire digital twins, multi-UAV competition stacks, and GPS-denied inspection.

911 Drone LIVE SIM Gazebo SITL & Route Telemetry

Loudspeaker-Equipped 911 Drone: Audible Evacuation Alert Routing

An airborne emergency warning system pairing Gazebo SITL flight simulations of a loudspeaker-equipped drone with coverage-constrained routing optimization. The drone utilizes geospatial address databases to plan energy-bounded routes, broadcasting audible evacuation orders to households ahead of rapid-onset wildfire frontlines.

Gazebo SITL Coverage-Constrained VRP Clarke-Wright Heuristics Geospatial Addresses PX4 Autopilot
SIM Thermal / RGB Blend (791°C)
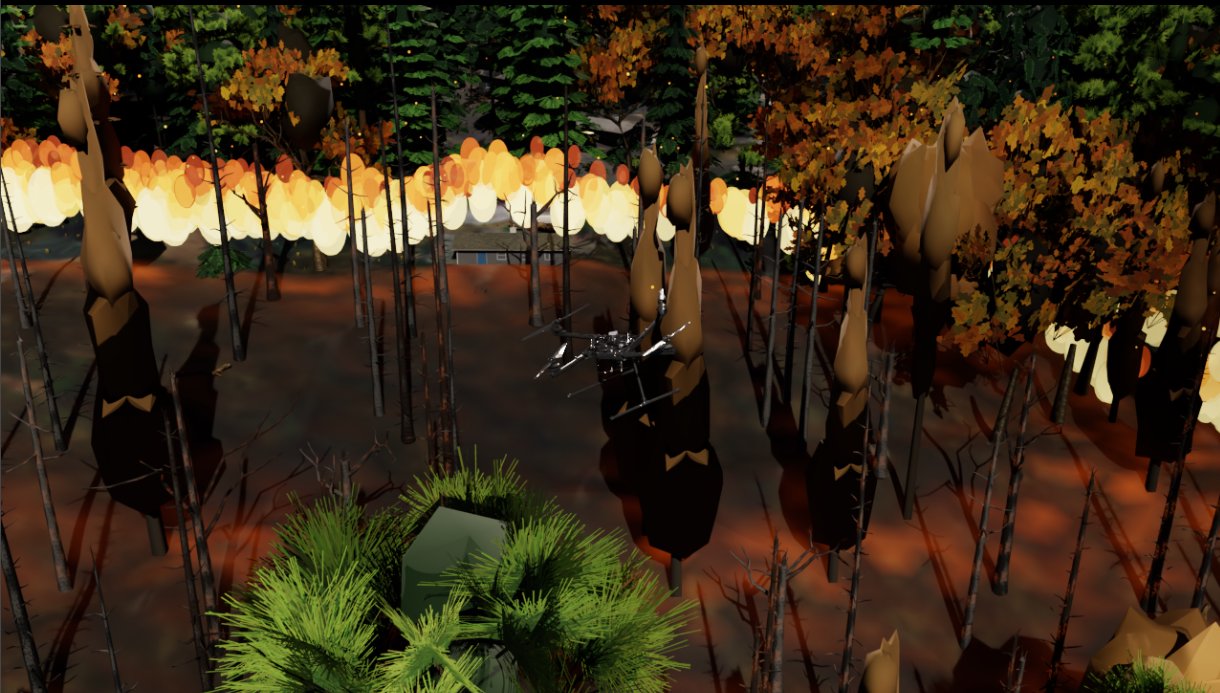
Freefly Alta X Flying in NVIDIA Isaac Sim 6.0 Over Active Fire Plume SIM Isaac Sim Alta X Fireline Chase
Wildfire Sim Isaac Sim 6.0

Alta X + Gremsy VIO G1 Wildfire Digital Twin

Physics-accurate simulation of the Freefly Alta X heavy-lift multirotor in NVIDIA Isaac Sim 6.0.1, flown by PX4 SITL over a 1 km² scene of Concow, CA (Camp Fire footprint). Synchronizes a direct sensor view capturing radiometric thermal IR + RGB side-by-side with a chase perspective of the Alta X flying inside the dynamic smoke plume.

NVIDIA Isaac Sim 6.0 PX4 SITL ROS 2 Humble ELMFIRE Gremsy VIO G1 Thermal/EO Fusion
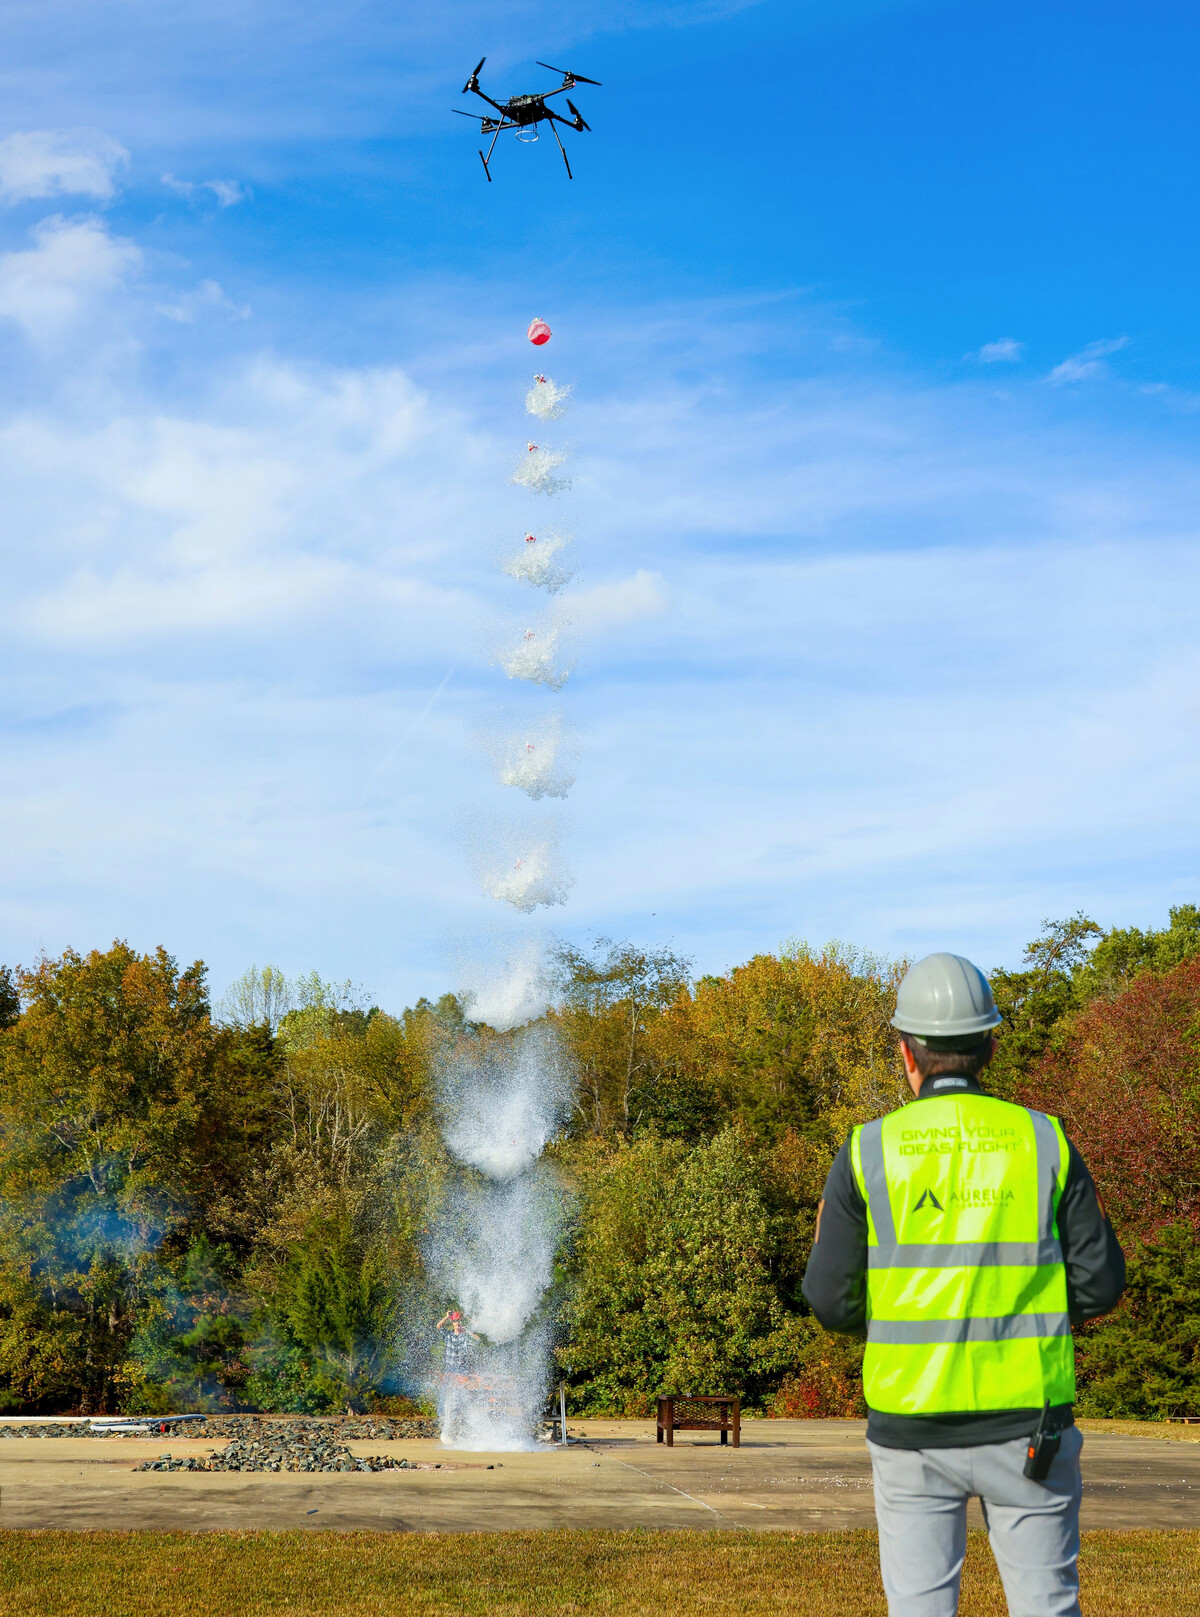
Team Crossfire Autonomous Water Drop - IEEE Spectrum IEEE Spectrum Field Test
QGC Offboard Mission Telemetry
XPRIZE Wildfire IEEE Spectrum Feature

Team Crossfire — XPRIZE Wildfire Autonomy Stack

Autonomy Technical Lead for UMD's Team Crossfire in the $11M global XPRIZE Wildfire competition. Leading autonomy-focused technical integration across sensing, companion computing, and flight controllers for autonomous detection, verification, and precision suppression handoffs. Featured in IEEE Spectrum chronicling our autonomous firefighting drone field tests.

Multi-UAV Coordination Thermal IR Vision ROS 2 PX4 Target Handoff IEEE Spectrum
Hardware-in-the-Loop (HITL) SFPE Finalist ($5K)

"Seeker-Firejumper" Multi-UAV Framework & HITL

An autonomous dual-drone framework presented at the SFPE WUI Summit (finalist winner of $5,000 USD grant with Adetola Koiki). "Seeker" drones leverage computer vision (YOLO) and radiometric thermal sensing to identify, detect, and georeference new ignitions, handing coordinates to "Firejumper" drones carrying precision suppression payloads. Validated via Hardware-in-the-Loop (HITL) flight testing.

Multi-Agent Coordination YOLO Fire Detection HITL Flight Testing Thermal Georeferencing WUI Fires

Research & Professional Experience

Professional and academic appointments in aerial robotics, autonomy research, competition technical leadership, and teaching.

Graduate Research Assistant
University of Maryland, College Park
Jan 2024 – Present
Department of Fire Protection Engineering & Department of Aerospace Engineering (Advisor: Dr. Fernando Raffan-Montoya | Co-Advisor: Dr. Lina Maria Castano)
  • Lead research on UAV autonomy and aerial sensing for wildfire monitoring and suppression under Dr. Fernando Raffan-Montoya and Dr. Lina Maria Castano.
  • Develop and integrate autonomy workflows using PX4 + ROS 2 for offboard mission orchestration, perception, and vehicle state estimation.
  • Build field-to-simulation pipelines in Gazebo Harmonic and NVIDIA Isaac Sim 6.0 to rigorously evaluate planning and perception algorithms.
  • Apply machine learning to improve robustness of aerial perception under degraded visual environments (smoke, thermal glare, and variable terrain).
  • Design flight experiments, collect field telemetry, and maintain reproducible software tooling for dataset curation and evaluation.
Technical Lead (Autonomy) — Team Crossfire
XPRIZE Wildfire Competition (University of Maryland & xFoundry)
Summer 2025 – Present
$11M Global Competition — Featured in IEEE Spectrum
  • Lead autonomy-focused technical workflows for competition missions, coordinating integration across sensing, companion computing, and flight controllers.
  • Prototype real-time perception and mapping pipelines for wildfire monitoring utilizing radiometric thermal and RGB sensors with geospatial GIS tools.
  • Support flight readiness: mission trajectory generation, pre-flight checklists, on-site troubleshooting, and post-flight telemetry analytics.
Graduate Research Assistant
Universidad de los Andes
Aug 2021 – Dec 2022
Department of Mechanical Engineering (Bogotá, Colombia 🇨🇴)
  • Supported an open-hardware microgrid modeling, monitoring, and proof-of-concept instrumentation project.
  • Developed data processing, filtering, and telemetry monitoring scripts in Python and assisted with experimental sensor calibration.
Teaching Assistant
Universidad de los Andes
Aug 2021 – Dec 2022
Department of Mechanical Engineering (Bogotá, Colombia 🇨🇴)
  • Planned and supervised introductory Mechanical Engineering laboratory activities and hands-on projects.
  • Guided undergraduate students through practical mechanical design concepts, experimental testing, and graded engineering laboratory reports.
New Technologies Laboratory Assistant
Universitaria de Colombia
Feb 2021 – Jul 2021
UAV Prototyping & Advanced Manufacturing (Bogotá, Colombia 🇨🇴)
  • Designed, prototyped, and assembled unmanned aircraft airframes and custom sensor mounts.
  • Managed CAD workflows (SolidWorks, Fusion 360, Autodesk Inventor) and rapid prototyping via 3D printing and composite laminates.

Education & Specialized Training

Formal engineering degrees, doctoral coursework, and specialized international training in aerial robotics autonomy and wildfire science.

PhD in Aerospace Engineering (In Progress)
University of Maryland, College Park
Jan 2024 – Present
  • Advisors: Dr. Fernando Raffan-Montoya (Fire Protection Engineering / FireTEC) & Dr. Lina Maria Castano (Aerospace Engineering).
  • Research Focus: UAV Autonomy & Aerial Sensing for Wildfire Management with Fire Protection Engineering.
  • Selected Coursework: ENAE788V Motion Planning for Autonomous Systems (Dr. Michael Otte); ENAE788M Hands-on Autonomous Aerial Robotics (Dr. Joseph Conroy).
1st International Summer Course on Robotics for Wildfires
ADAI — Association for the Development of Industrial Aerodynamics / University of Coimbra (Coimbra, Portugal 🇵🇹)
June 8–12, 2026
  • Certificate of Attendance: Advanced multidisciplinary training in aerial robotics, autonomous systems, remote sensing, artificial intelligence, and decision support technologies for wildfire prevention, monitoring, suppression, and post-fire management.
  • Hands-on Activities: Practical fieldwork, operational demonstrations, and lectures delivered by international leaders in wildfire science and field robotics.
M.Sc. in Mechanical Engineering
Universidad de los Andes (Bogotá, Colombia 🇨🇴)
2021 – 2023
  • Master's Thesis: Clasificación del estado de módulos fotovoltaicos a partir de datos sintéticos mediante modelado y algoritmos computacionales.
  • Relevant Coursework: Machine Learning; Mechanical Design and Innovation; Computer Design of Mechanisms.
B.Sc. in Mechanical Engineering
Universidad de los Andes (Bogotá, Colombia 🇨🇴)
2016 – 2020
  • Relevant Coursework: Control Systems; Materials Engineering; Manufacturing Systems; Energy Conversion; Mechanical Systems Design.

Publications & Media Coverage

Journal papers, conference presentations, major engineering media features, and peer review contributions.

Media Coverage — IEEE Spectrum

How Drones Are Fighting Wildfires — Team Crossfire Field Tests

Chronicling Andrés Felipe Rivas Bolívar and Team Crossfire (University of Maryland & xFoundry)

IEEE Spectrum — Emerging Disaster Response Technologies

Feature chronicling Team Crossfire's autonomous drone operations, sensor payload integration, and live flight tests conducting precision water and suppression drops in the $11M XPRIZE Wildfire competition.

Grant Winner & Coverage — SFPE Foundation

Finalist Winner ($5,000 USD Grant) — 2026 WUI Fire Engineering Summit

Andrés Felipe Rivas Bolívar & Adetola Ololade Nicole Koiki (Supervisor: Dr. Fernando Raffan-Montoya)

SFPE Foundation & United Engineering Foundation (UEF) — Student Pitch Competition

Selected as finalist winners of the $5,000 USD research grant in the Student Pitch Competition for pioneering research on wildfire ember (firebrand) detection, 3D tracking, and autonomous mitigation in wildland-urban interface (WUI) scenarios, conducted at the UMD Fire Protection Engineering FireTEC laboratory.

Television News Feature — FOX 5 DC (WTTG)

Autonomous Wildfire Defense Drones — UMD Team Crossfire Feature

Highlighting Andrés Felipe Rivas Bolívar and Team Crossfire (University of Maryland)

FOX 5 News DC (WTTG) — Broadcast & Digital News Feature

Television broadcast feature on Team Crossfire's autonomous firefighting drones developed for the $11M XPRIZE Wildfire competition, highlighting live flight tests, AI edge computing, and precision water drops extinguishing test burns.

Research Paper

A Coverage Constrained Routing Approach for Broadcasting Audible Emergency Evacuation Alerts with UAVs

Andrés Felipe Rivas Bolívar, et al.

IEEE Robotics & Automation Society / Emergency Management Robotics

Presents an airborne emergency warning system where loudspeaker-equipped UAVs use geospatial address databases to plan optimized routes that maximize household reach under strict battery, service time, and operational constraints.

Conference Poster Presentation

Autonomous Unmanned Aerial Vehicle (UAV) Applications in Wildland-Urban-Interface (WUI) Fire Scenarios

Author: Andrés Felipe Rivas Bolívar

2026 Wildland-Urban Interface (WUI) Fire Engineering Summit — Digital Technology Track (Poster DT-2)

Official Abstract

When a Wildland-Urban Interface fire ignites, the window for safe evacuation can be measured in minutes. This presentation introduces an autonomous "Seeker-Firejumper" UAV framework designed to detect and suppress incipient wildfires before they threaten escape routes. A Seeker drone, equipped with a custom computer-vision model and an onboard companion computer, autonomously identifies and georeferences new ignition points in real time. It then hands off the target coordinates to a Firejumper drone carrying a smart suppression payload that delivers a localized drop over the fire. We will share how the full autonomy pipeline, built on ROS 2 and PX4, was validated through Software-in-the-Loop and Hardware-in-the-Loop missions, alongside field tests of the suppression mechanism. By moving from passive aerial observation to active, autonomous suppression, this work offers incident commanders a new tool to slow fire spread and protect WUI communities at the earliest stages.

Peer Review Service

Reviewer — IEEE International Conference on Intelligent Robots and Systems (IROS 2026)

Peer review of research on UAV photogrammetry, online trajectory planning, and autonomous multi-view reconstruction under energy budgets.

Technical Skills & Toolchains

Multidisciplinary proficiencies spanning flight autonomy, physics simulations, telemetry networks, computer vision, and hardware engineering.

Robotics & Autonomy

PX4 Autopilot ROS 2 Humble MAVLink / MAVROS Micro-XRCE-DDS QGroundControl Offboard Flight Control Motion Planning

Simulation & Digital Twins

Python 6-DOF Dynamics NVIDIA Isaac Sim 6.0 Gazebo Harmonic Pegasus Simulator ELMFIRE Wildfire PhysX Tensor Dynamics

Perception & Machine Learning

Radiometric Thermal IR Vision-Language Models (VLMs) YOLO11 / YOLOv8 OpenCV PyTorch Stereo & Depth Triangulation

Telemetry & Networking

Robotics Telemetry Networks Low-Latency RTSP Video ZeroMQ / UDP / TCP Micro-XRCE-DDS Agent MAVLink Gimbal & Sensors

Hardware & Prototyping

Multirotor Avionics PX4 Flight Tuning Freefly Alta X Gremsy VIO G1 / SIYI A8 Payload Integration 3D Printing & Prototyping

Languages & Engineering CAD

Python (NumPy, SciPy) C++ MATLAB SolidWorks Autodesk Inventor Fusion 360 Spanish (Native) / English (C1)

Let's Connect

I am actively interested in discussing aerial robotics research collaborations, field autonomy deployments, and technical R&D opportunities.

Email
Location
College Park, Maryland, United States
Origin
Bogotá, Colombia 🇨🇴
Work Authorization
F-1 Visa (CPT & STEM-OPT Eligible)
LinkedIn GitHub Academic CV

Send a Message

Have a research inquiry or technical question? Feel free to reach out.